Introduction: Unlock Remote Physical Control with ESP32
The ESP32 is more than a microcontroller; it’s a gateway to the Internet of Things (IoT). By combining its Wi-Fi capability with a simple servo motor, you can create interactive projects that you control from any device on your local network. This comprehensive guide will walk you through building a web server with the ESP32 that lets you control a servo motor in real-time using a slider on a webpage.
Whether you’re aiming to build a smart pet feeder, a remote-controlled camera mount, or a prototype for a connected device, mastering this skill is fundamental. This tutorial is designed not only to make your project work but to help you understand the underlying principles of web servers, PWM control, and safe hardware interfacing, following best practices for reliability and performance.
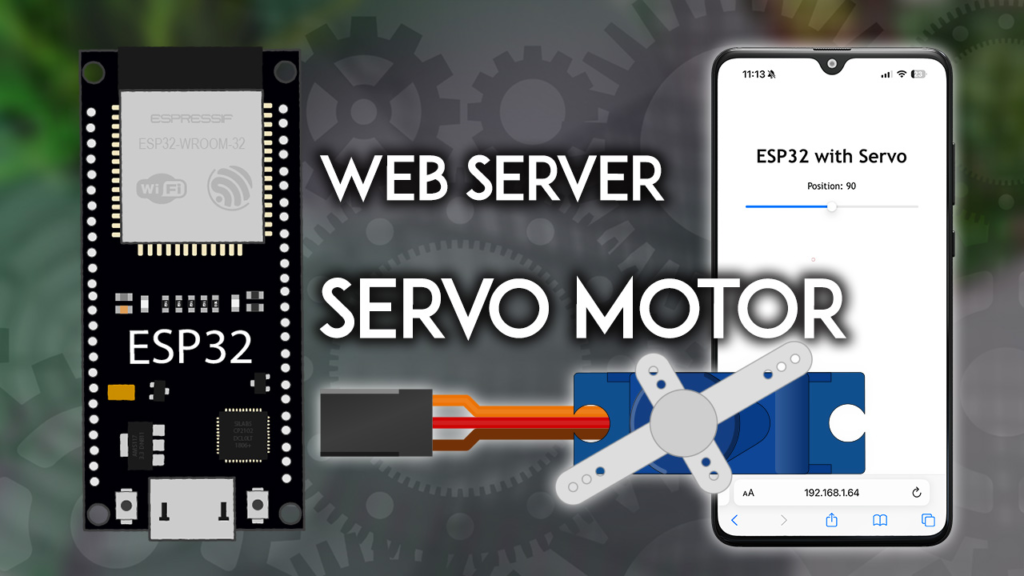
1. Understanding the Hardware: Servo Motors and the ESP32
1.1 Servo Motor Basics
A servo motor is a compact device that rotates its shaft to a precise angular position, typically between 0 and 180 degrees. Unlike regular motors that spin continuously, servos are designed for controlled movement. They contain a small DC motor, gears, and control circuitry. They are controlled by a Pulse Width Modulation (PWM) signal, where the width of the electrical pulse (usually between 1ms and 2ms) determines the shaft’s position.
Common Servo Wire Color Code:
-
Power (VCC): Red
-
Ground (GND): Black or Brown
-
Signal (PWM): Yellow, Orange, or White
1.2 Critical Power Considerations
⚠️ The most common mistake is powering the servo directly from the ESP32‘s 3.3V pin for anything but the smallest micro-servos.
-
Small Servo (e.g., SG90): Can be powered from the ESP32‘s VIN pin (if your USB provides 5V) for simple testing. The VIN pin provides the input voltage from your USB or external power supply (usually 5V).
-
Standard or Multiple Servos: You must use an external 5V power supply. A servo in motion can draw significant current (hundreds of mA), causing voltage drops that can reset your ESP32 or damage its voltage regulator.
-
Safe Wiring for External Power: Connect the external power’s 5V and GND to your breadboard’s power rails. Connect the servo’s power wire to the 5V rail and its ground wire to the GND rail. Crucially, also connect this external GND rail to one of the ESP32‘s GND pins. This creates a common ground, which is essential for the signal to be interpreted correctly.
1.3 ESP32 GPIO Selection for Servo
While the ESP32 can generate PWM on most GPIOs, some pins have restrictions:
-
Recommended PWM Pins: GPIOs 13, 12, 14, 27, 26, 25, 33, 32 are generally safe and easy to use.
-
Pins to Avoid: GPIOs 34, 35, 36, 39 are input-only and cannot be used for PWM output.
-
Use with Caution: GPIOs 6, 7, 8, 9, 10, 11 are often connected to the integrated flash memory and are not recommended for other uses to prevent crashes.
For this tutorial, we will use GPIO 13.
2. Required Components & Wiring Diagram
2.1 Components List
-
ESP32 Development Board (e.g., ESP32 DEVKIT DOIT)
-
Micro Servo Motor (e.g., SG90 or MG90S)
-
Breadboard and Jumper Wires (Male-to-Male)
-
Micro-USB Cable for programming and power.
-
(Recommended) External 5V Power Supply (e.g., a bench power supply or a dedicated 5V adapter with a DC barrel jack).
2.2 Wiring Schematic
Follow this diagram to connect your components. The diagram assumes the use of the ESP32‘s VIN pin for servo power for simplicity, but remember the power considerations above.
        Servo Motor
        -----------
        |         |
    Red (PWR) ----> ESP32 VIN Pin
    Brown (GND) --> ESP32 GND Pin
    Orange (SIG) --> GPIO 13
Expert Tip: If using an external 5V supply, connect the servo’s PWR and GND to the external supply’s rails, and connect the GND rail to the ESP32‘s GND.
3. Software Setup: Arduino IDE and Libraries
3.1 Installing the ESP32 Board Manager
-
Open Arduino IDE, go to File > Preferences.
-
In “Additional Boards Manager URLs,” paste: https://raw.githubusercontent.com/espressif/arduino-esp32/gh-pages/package_esp32_index.json
-
Go to Tools > Board > Boards Manager, search for “esp32”, and install the “Espressif Systems” platform.
3.2 Installing the Essential Library
We will use the ESP32Servo library, which handles the complex timer configurations of the ESP32 for us.
-
In Arduino IDE, go to Sketch > Include Library > Manage Libraries…
-
Search for “ESP32Servo” by Kevin Harrington and Mads Hobye.
-
Click “Install”.
4. Core Code: Building the Web Server
Below is the complete, annotated code for your ESP32 servo web server. Copy it into your Arduino IDE.
#include <WiFi.h>
#include <ESP32Servo.h>
Servo myServo;
static const int servoPin = 13;
const char* ssid = "YOUR_WIFI_SSID";
const char* password = "YOUR_WIFI_PASS";
WiFiServer server(80);
String currentPosition = "90";
unsigned long currentTime = millis();
unsigned long previousTime = 0;
const long timeoutTime = 5000;
void setup() {
Serial.begin(115200);
myServo.attach(servoPin);
myServo.write(90);
delay(1000);
Serial.print("Connecting to ");
Serial.println(ssid);
WiFi.begin(ssid, password);
while (WiFi.status() != WL_CONNECTED) {
delay(500);
Serial.print(".");
}
Serial.println("\nWiFi connected.");
Serial.print("IP address: ");
Serial.println(WiFi.localIP());
server.begin();
Serial.println("HTTP server started. Open the IP address in your browser.");
}
void loop() {
WiFiClient client = server.available();
if (client) {
Serial.println("New Client connected.");
String currentLine = "";
String header = "";
currentTime = millis();
previousTime = currentTime;
while (client.connected() && currentTime - previousTime <= timeoutTime) {
currentTime = millis();
if (client.available()) {
char c = client.read();
Serial.write(c);
header += c;
if (c == '\n') {
if (currentLine.length() == 0) {
client.println("HTTP/1.1 200 OK");
client.println("Content-type:text/html");
client.println("Connection: close");
client.println();
client.println("<!DOCTYPE html><html>");
client.println("<head><meta name=\"viewport\" content=\"width=device-width, initial-scale=1\">");
client.println("<link rel=\"icon\" href=\"data:,\">");
client.println("<style>");
client.println("body { text-align: center; font-family: Arial, sans-serif; margin-top: 50px;}");
client.println(".slider { width: 80%; max-width: 400px; margin: 20px auto; }");
client.println("</style>");
client.println("<script src=\"https://ajax.googleapis.com/ajax/libs/jquery/3.6.0/jquery.min.js\"></script>");
client.println("</head><body>");
client.println("<h1>ESP32 Servo Controller</h1>");
client.println("<p>Current Position: <strong><span id=\"posText\">" + currentPosition + "</span>°</strong></p>");
client.println("<input type=\"range\" min=\"0\" max=\"180\" value=\"" + currentPosition + "\" class=\"slider\" id=\"servoSlider\">");
client.println("<script>");
client.println("var slider = $('#servoSlider');");
client.println("var posText = $('#posText');");
client.println("slider.on('input change', function() {");
client.println(" var pos = $(this).val();");
client.println(" posText.text(pos);");
client.println(" $.get('/?value=' + pos);");
client.println("});");
client.println("</script>");
client.println("</body></html>");
client.println();
if (header.indexOf("GET /?value=") >= 0) {
int valueStart = header.indexOf('=');
int valueEnd = header.indexOf(' ', valueStart);
String valueStr = header.substring(valueStart + 1, valueEnd);
if (valueStr.toInt() >= 0 && valueStr.toInt() <= 180) {
currentPosition = valueStr;
myServo.write(valueStr.toInt());
Serial.println("Servo moved to: " + valueStr + " degrees");
}
}
break;
} else {
currentLine = "";
}
} else if (c != '\r') {
currentLine += c;
}
}
}
client.stop();
Serial.println("Client disconnected.\n");
}
}
4.1 How the Code Works: Key Sections Explained
-
Network & Server Setup: The code connects to your Wi-Fi and starts a web server on port 80. The WiFi.localIP() printed to the Serial Monitor is the address you’ll type into your browser.
-
HTML Interface: The server sends a minimalist, mobile-friendly webpage containing a title, a display of the current angle, and a slider (<input type="range">).
-
JavaScript (AJAX): The magic of smooth, no-refresh updates happens here. The $.get('/?value=' + pos) jQuery command sends a background HTTP GET request to the ESP32 every time you move the slider, passing the new position.
-
Request Parsing: In the loop(), the ESP32 constantly checks incoming client data. When it detects a request string like /?value=45, it extracts the number 45, converts it to an integer, and commands the servo to move to 45 degrees using myServo.write().
5. Upload, Test, and Troubleshoot
5.1 Steps to Run Your Project
-
Replace Credentials: In the code, change YOUR_WIFI_SSID and YOUR_WIFI_PASS to your actual 2.4 GHz network details.
-
Upload: Connect your ESP32 via USB, select the correct board (e.g., “DOIT ESP32 DEVKIT V1”) and port in the Arduino IDE, and upload the code.
-
Get the IP Address: Open the Serial Monitor (Tools > Serial Monitor) at 115200 baud. After connecting to Wi-Fi, the ESP32 will print its IP address (e.g., 192.168.1.100).
-
Control the Servo: Open a web browser on any device connected to the same local network and type in the IP address. You should see the control page. Move the slider, and your servo should move in real time.
5.2 Troubleshooting Common Issues
6. Taking Your Project Further
Congratulations on building your basic web server! Here are ways to expand its functionality:
-
Multiple Servo Control: Duplicate the Servo object and HTML slider elements to control 2 or 3 servos independently (remember to use external power!).
-
Stylish Interface: Use CSS frameworks like Bootstrap to create a professional-looking control panel with buttons for preset positions (e.g., “Open,” “Close,” “45°”).
-
Secure Access: Implement password protection on the webpage or use ESP32‘s HTTPS capabilities for secure communication.
-
Internet (IoT) Control: Use a service like Blynk, IoT MQTT, or ESP32‘s built-in WebSocket support to control the servo from anywhere in the world.
-
Physical Feedback: Add a potentiometer to read the servo’s actual position and display it on the web page for a closed-loop system.
This guide synthesizes practical steps with crucial contextual knowledge about power management and network communication. By understanding both the “how” and the “why,” you are now equipped to integrate servo motors into robust, reliable ESP32 IoT projects.
Contact Us